,triangulation plane ,andby . ForaGiven , triangulation, :
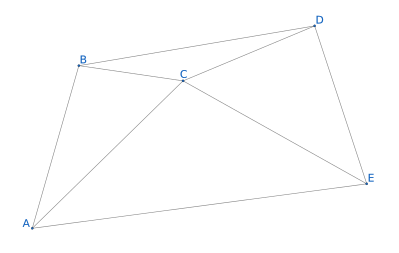
OI triangulation triangulation( Delaunay triangulation, call DT).
Delaunay triangulation
Definition
sumcalculate ,ForGiven plane , Delaunay triangulation DT() satisfy:
- :DT() ** ** (arbitrary cannot ), DT() ,arbitrary range exist.
- maximum minimum : triangulation ,DT() minimum maximum. ,DT() ** ** triangulation. two form edge , ,two minimum .
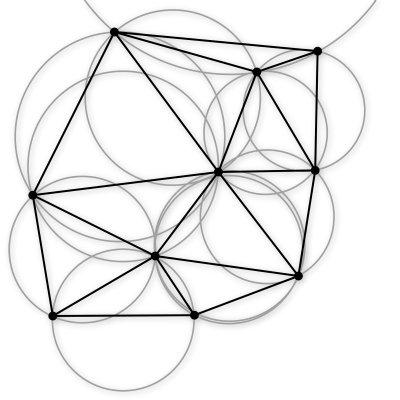
Properties
- : , segment( edge) .
- : , obtain ( arbitrary cannot ).
- optimal :arbitrarytwo form edge Ifcan , two minimum .
- :If triangulation each minimum row column, Delaunay triangulation columnobtain valuemaximum.
- : 、 、 a .
- edge :triangulation edge a polygon .
DT algorithm
DT algorithm, algorithm , algorithm sumImplementation .
DT Given ** ** column,as followsgraph size .
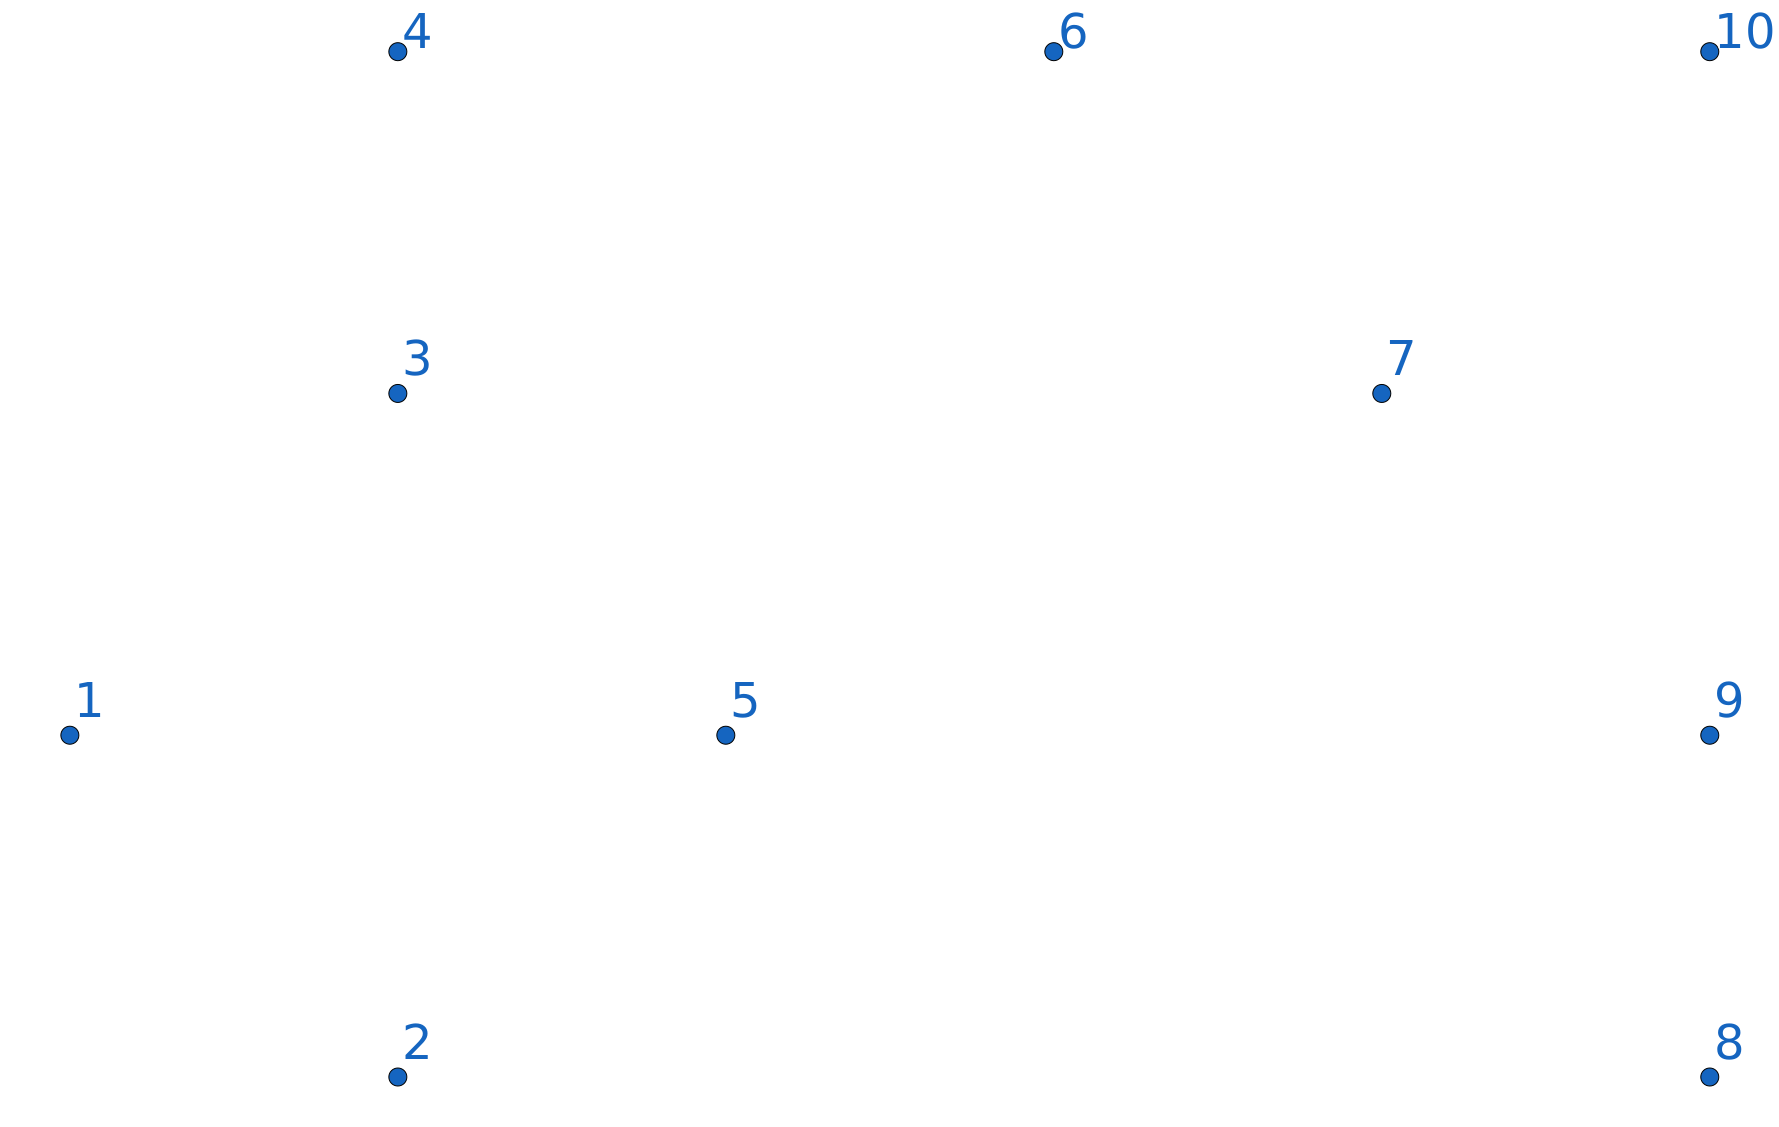
, can divide intotwo ( ), sizeno greater than . can a segment.
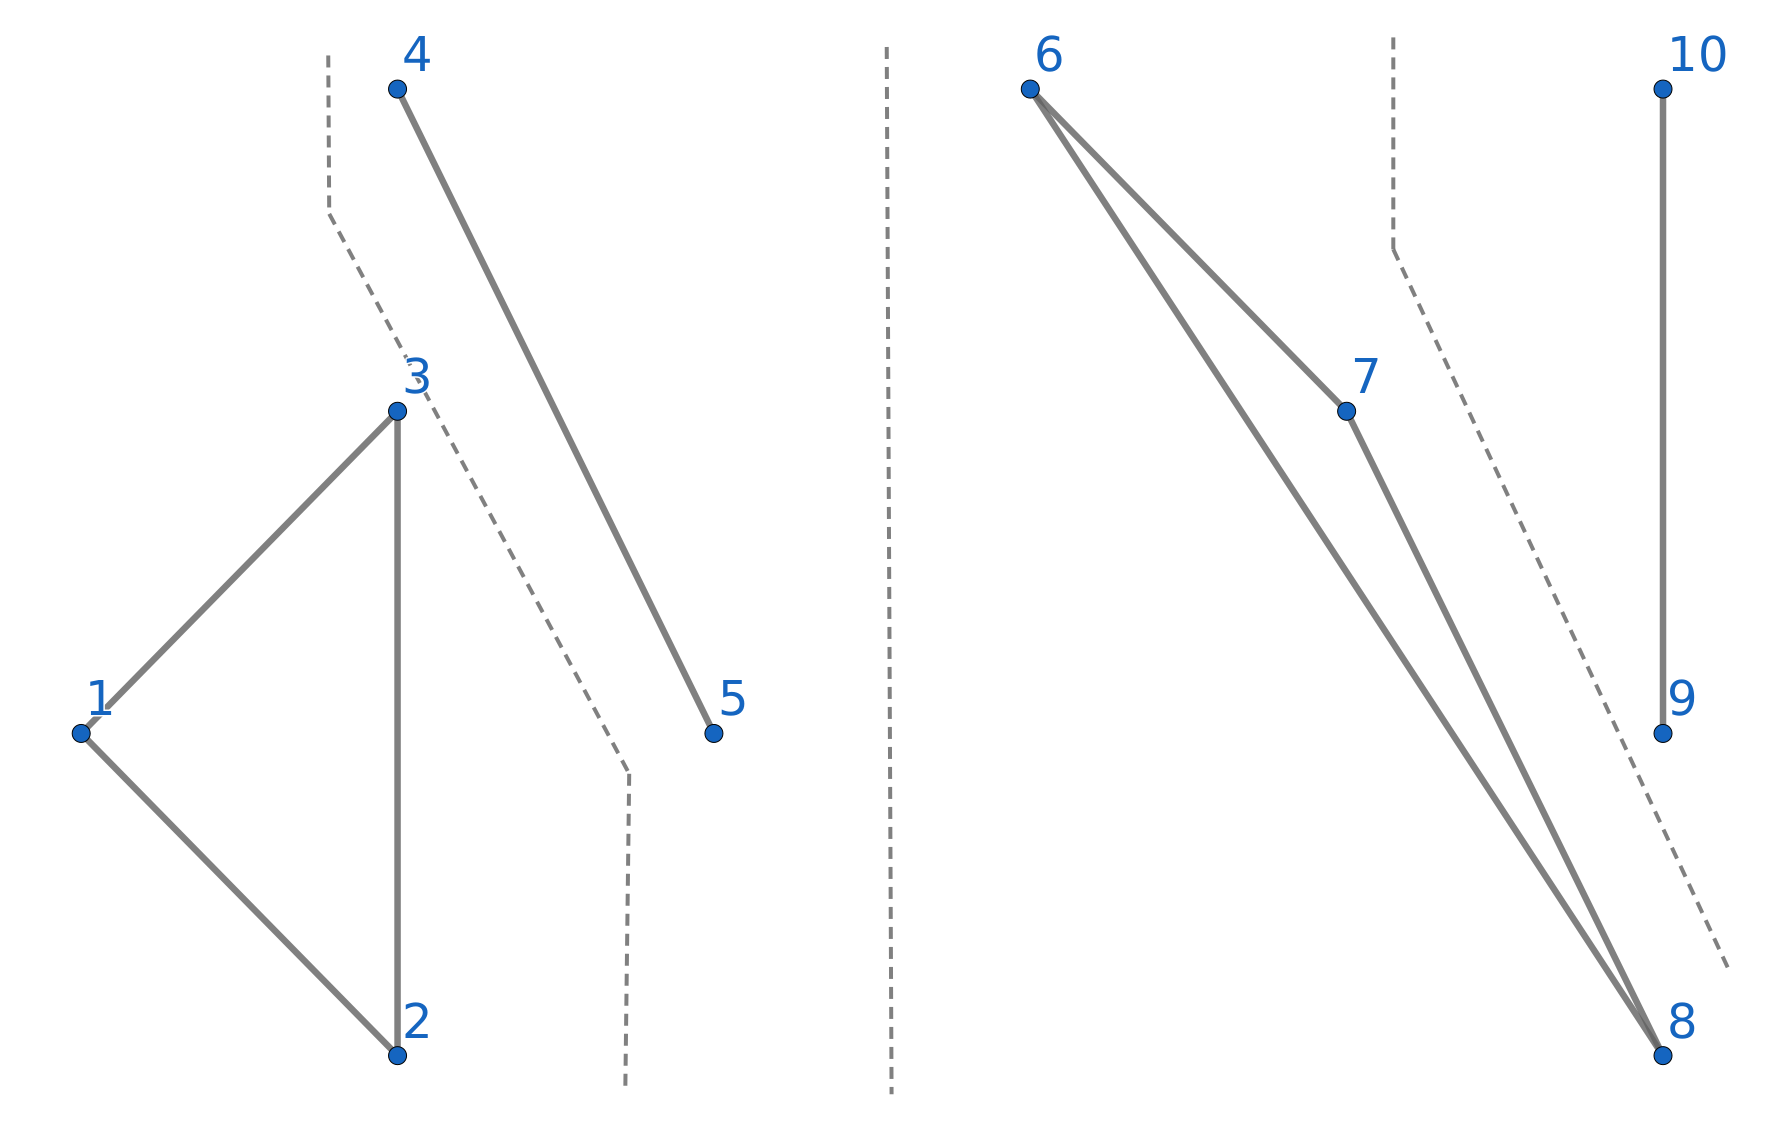
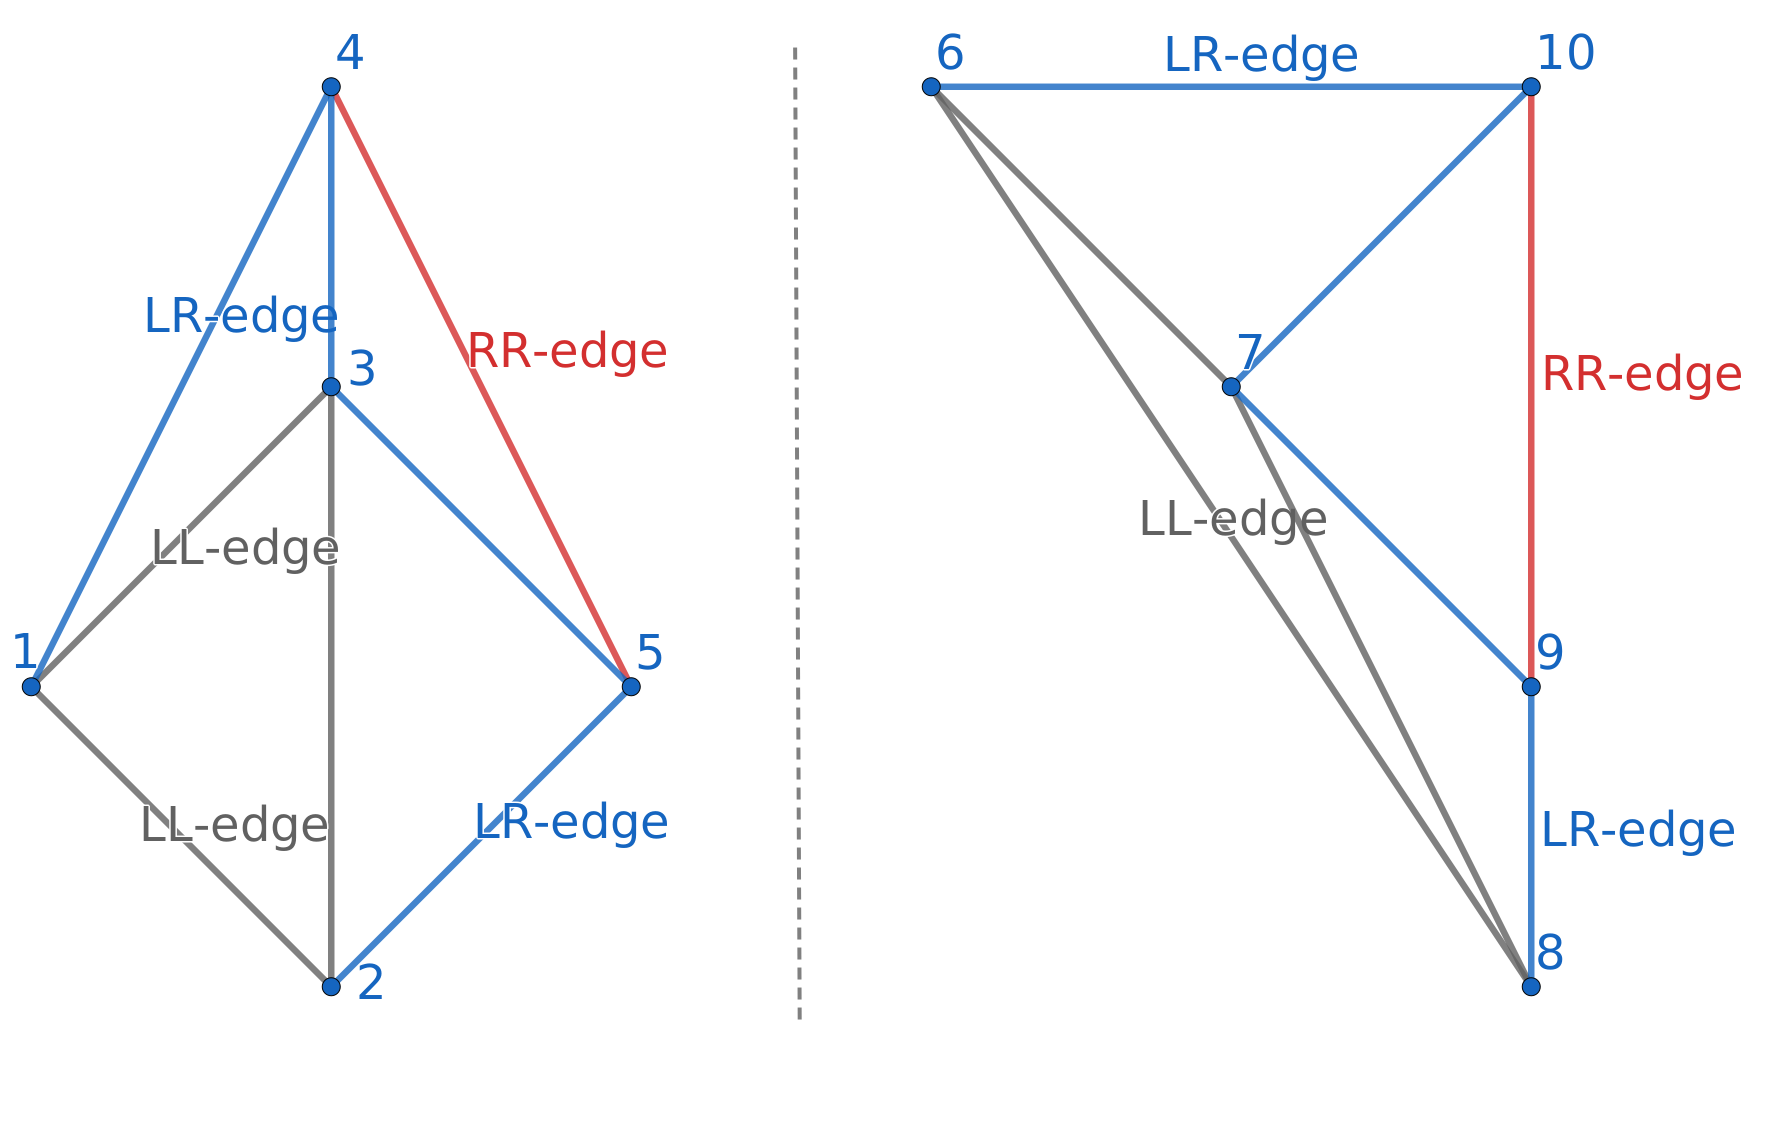
process , can merge.merge contain LL-edge( edge).RR-edge( edge),LR-edge( edge), graph LL-edge( ),RR-edge( ),LR-edge( ).Formerge , DT property, ** ** need to LL-edge sum RR-edge, merge ** ** LL-edge sum RR-edge.
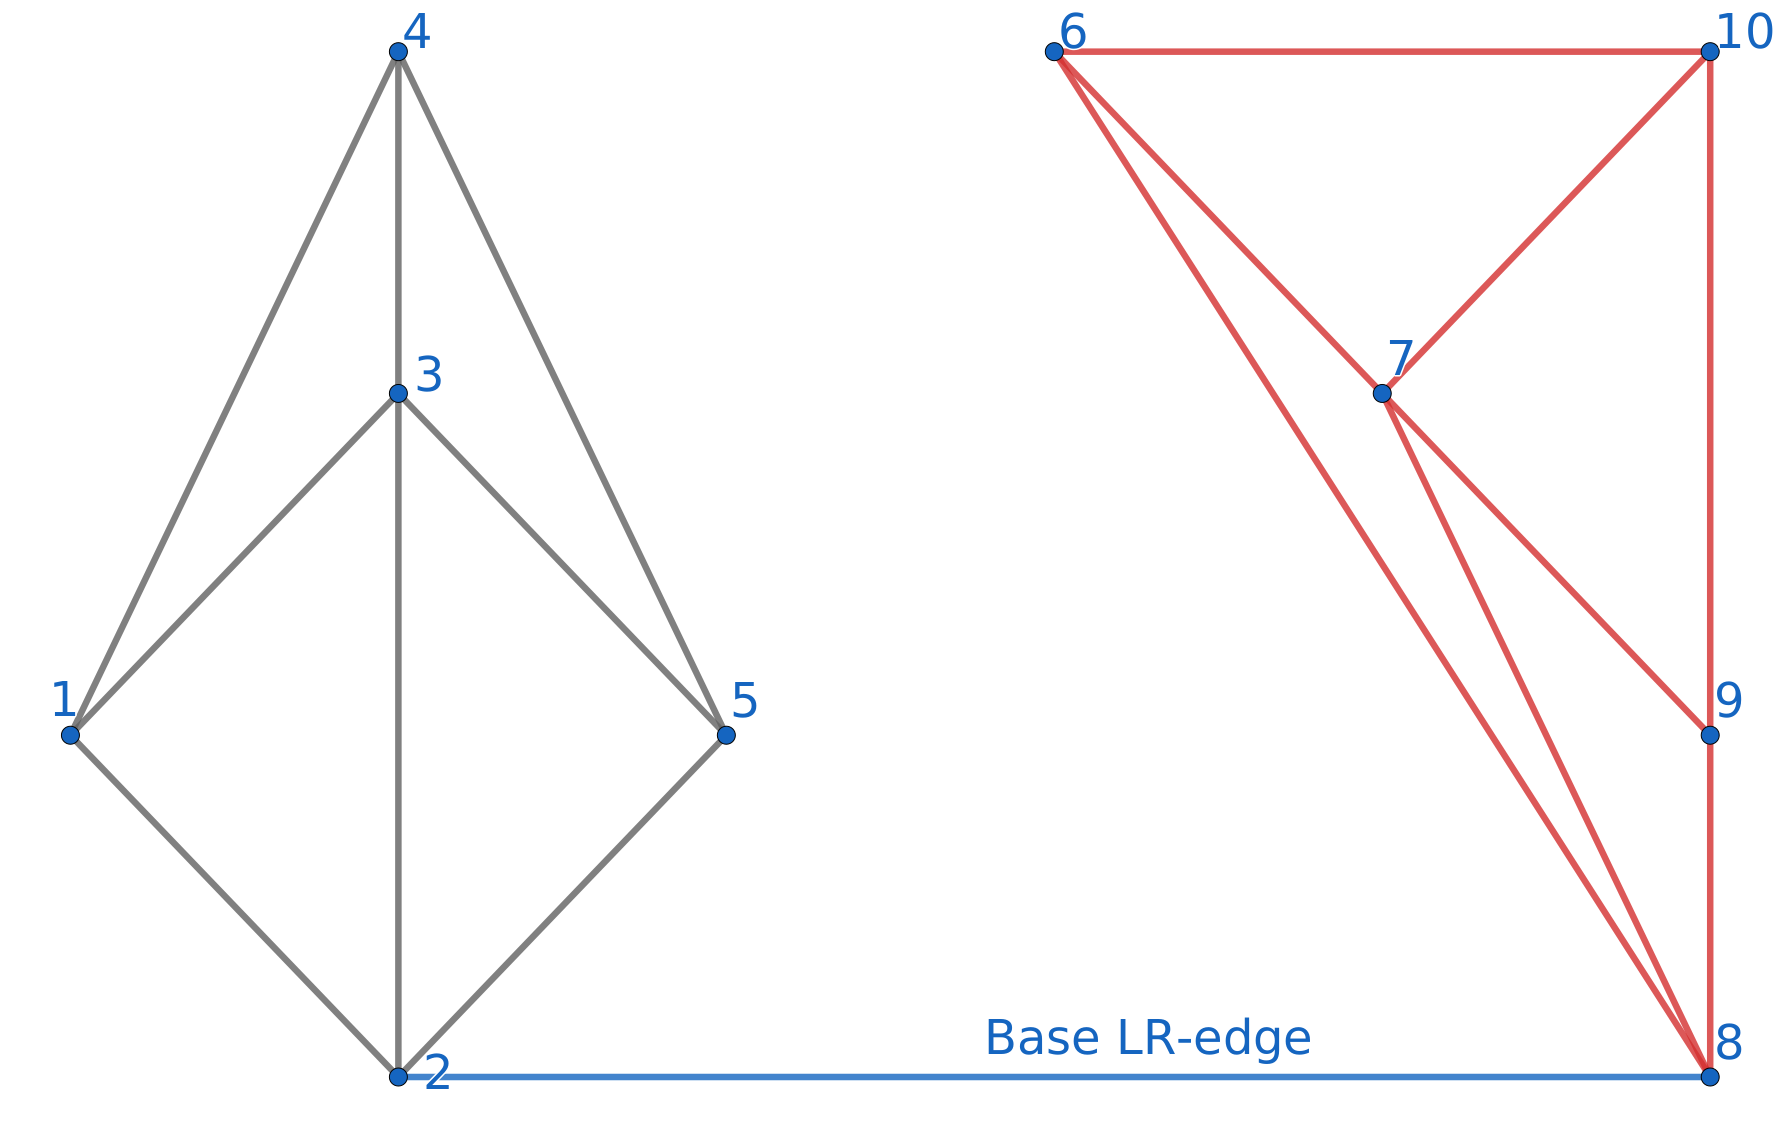
merge two base LR-edge,base LR-edge ** ** ** ** LL-edge RR-edge LR-edge.
, need to ** ** base LR-edge LR-edge. For , LR-edge ( ) base LR-edge RR-edge ( ), .
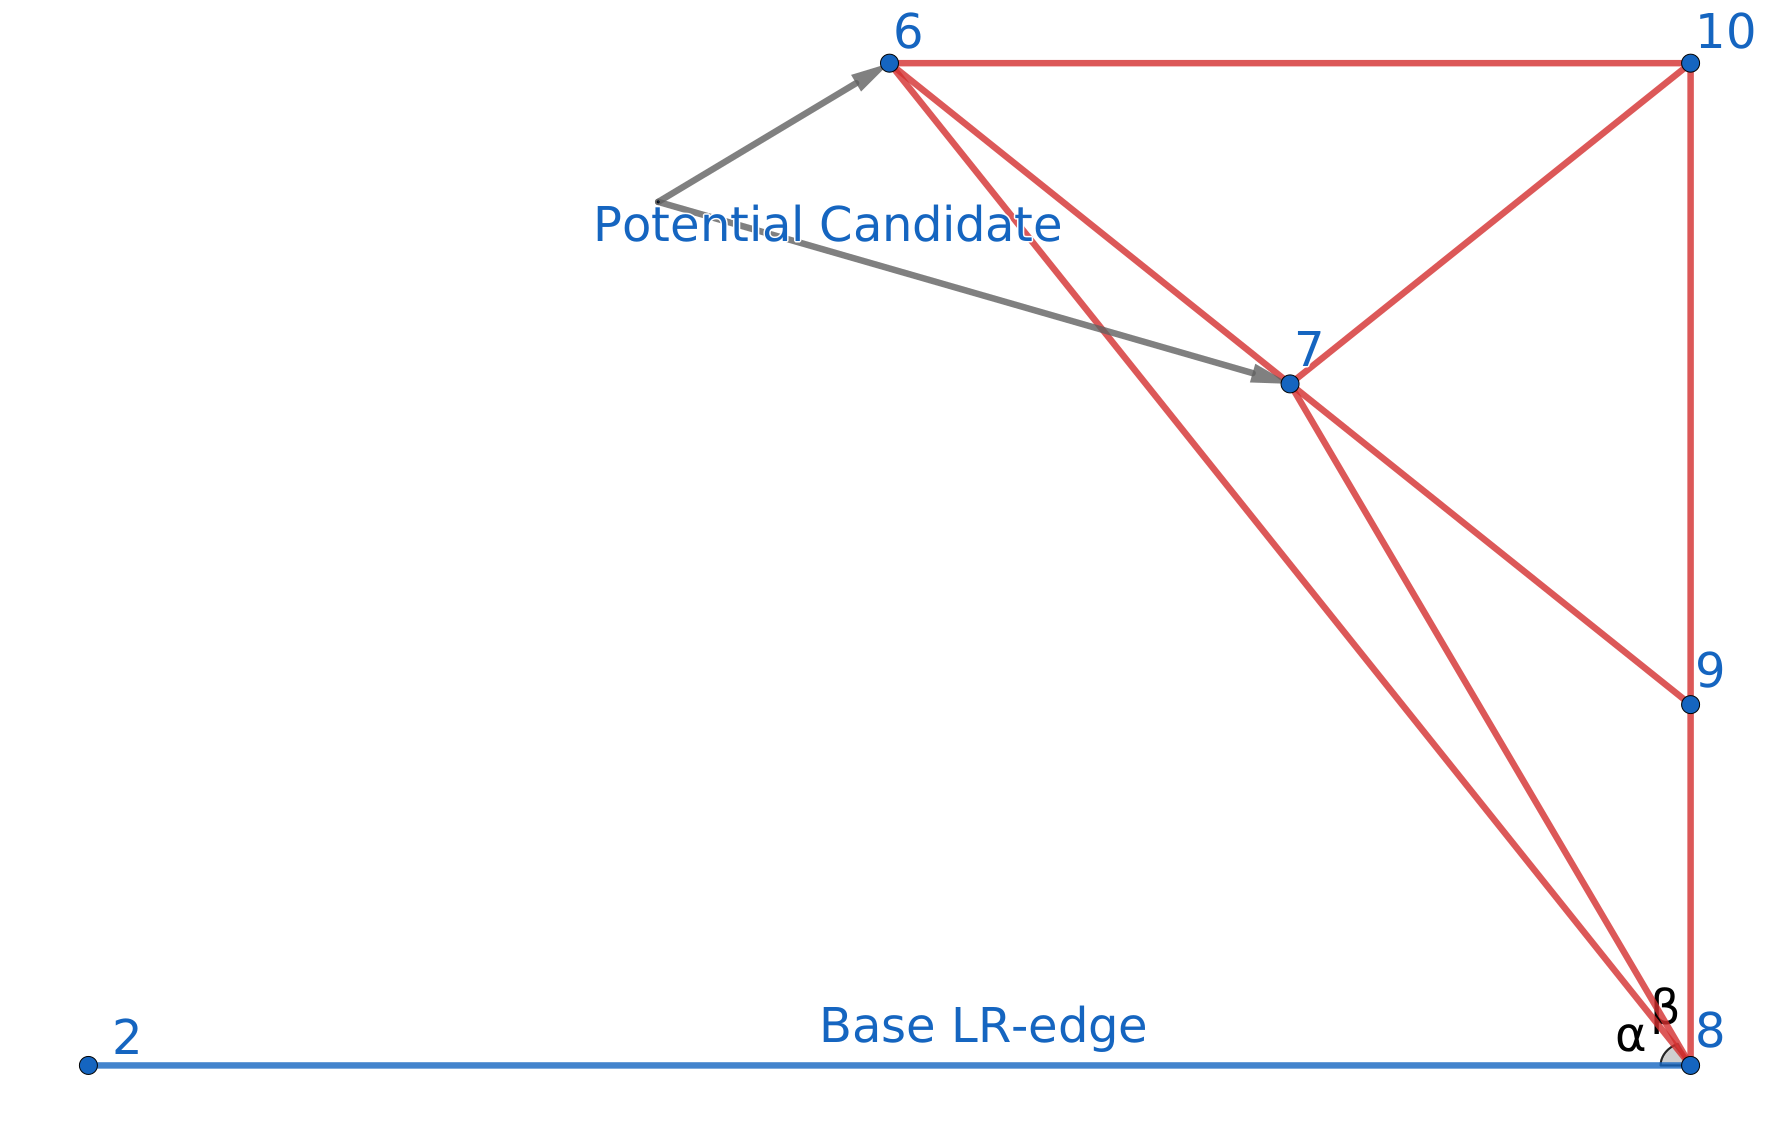
For , need to two :
- corresponding RR-edge base LR-edge less than .
- base LR-edge sum form contain ** **.
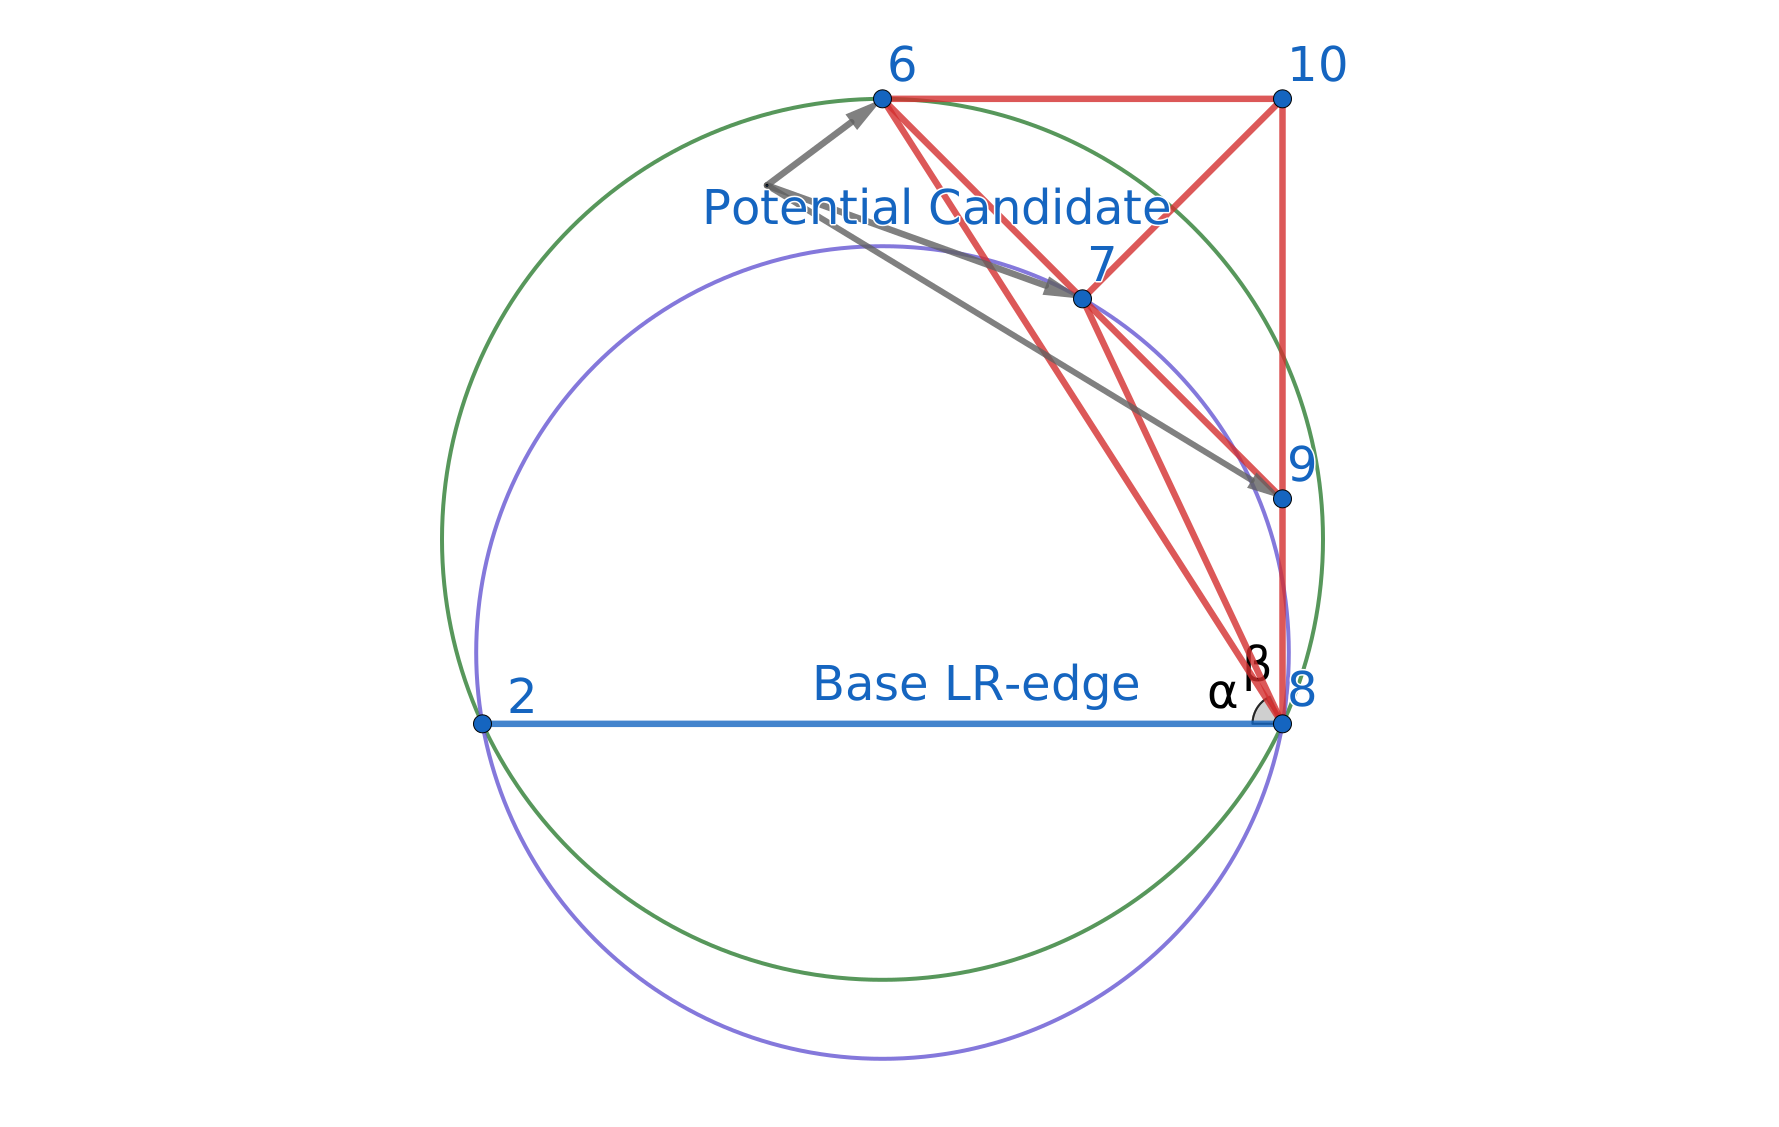
graph, corresponding contain , corresponding contain , LR-edge .
For , .
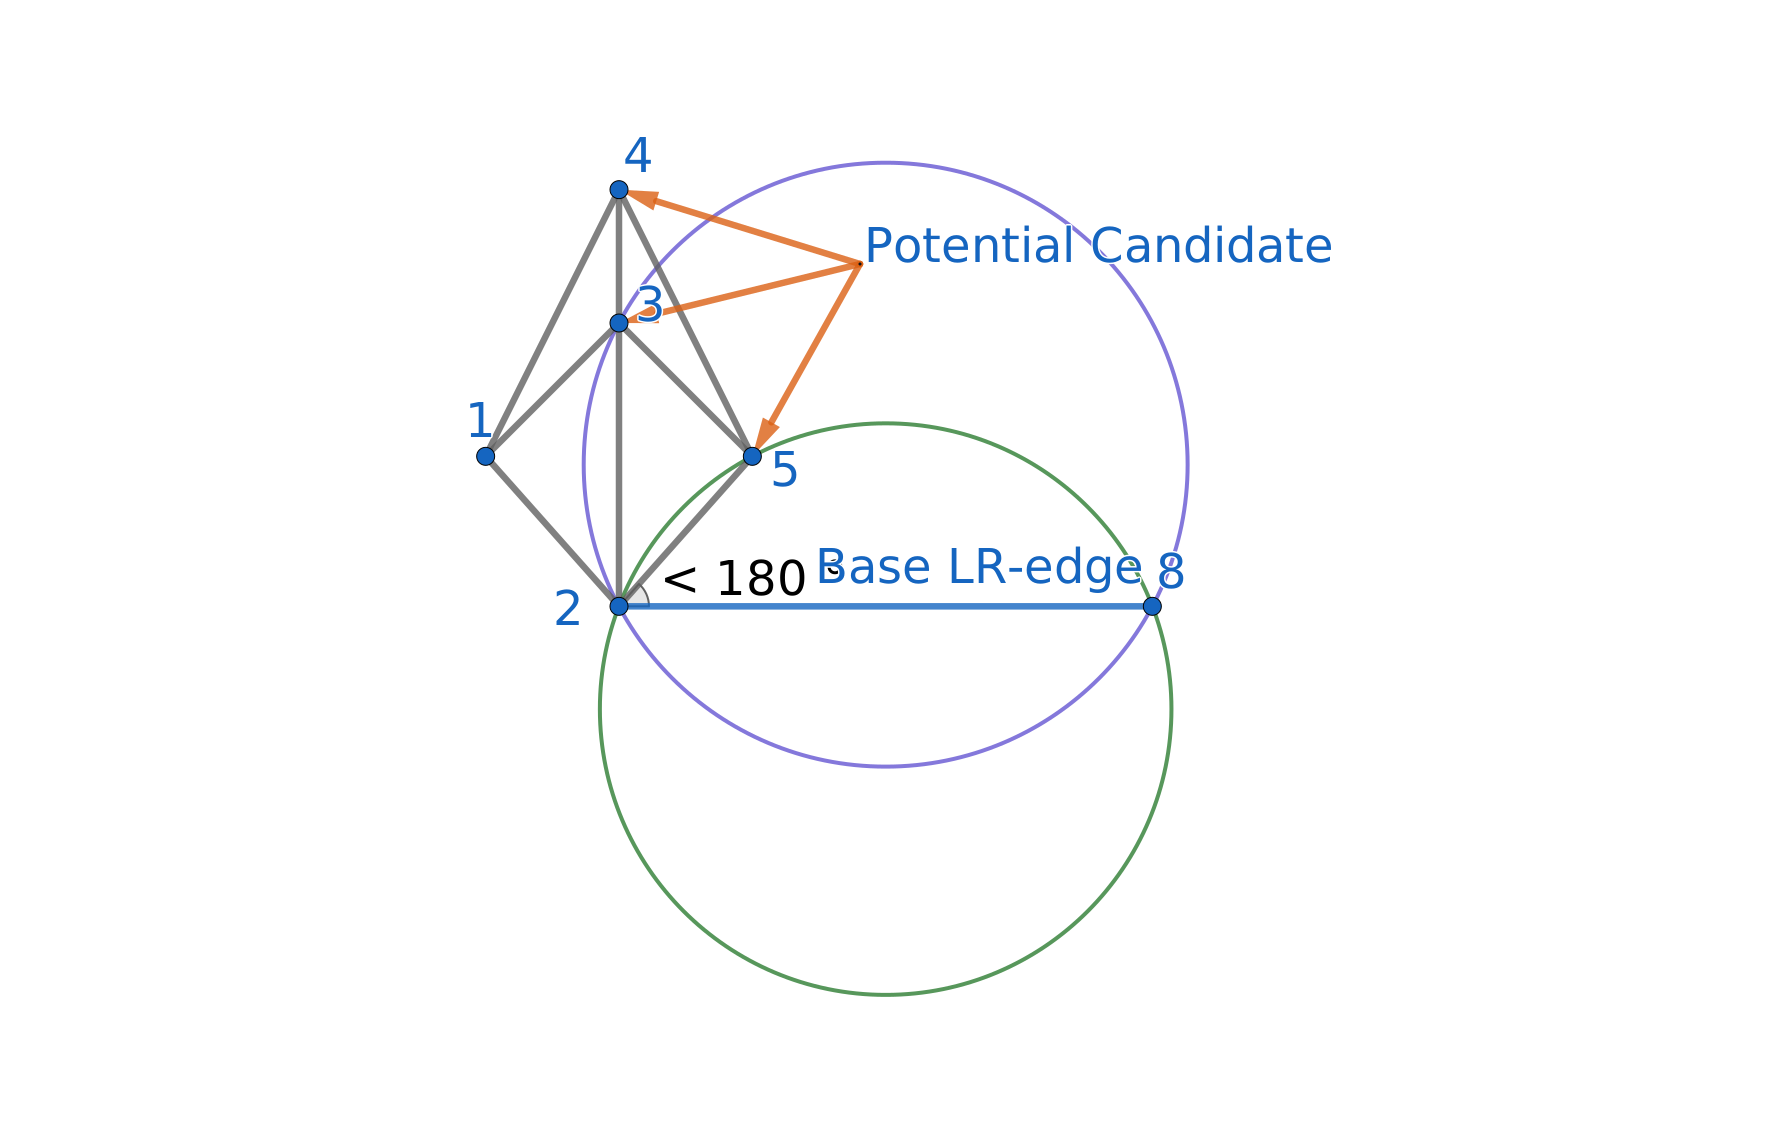
When ,merge .Whena , LR-edge need to ,For need to LR-edge LL-edge sum RR-edge, .
When exist , edge corresponding contain edge ,Ifcontain ;For edge . a ( ).
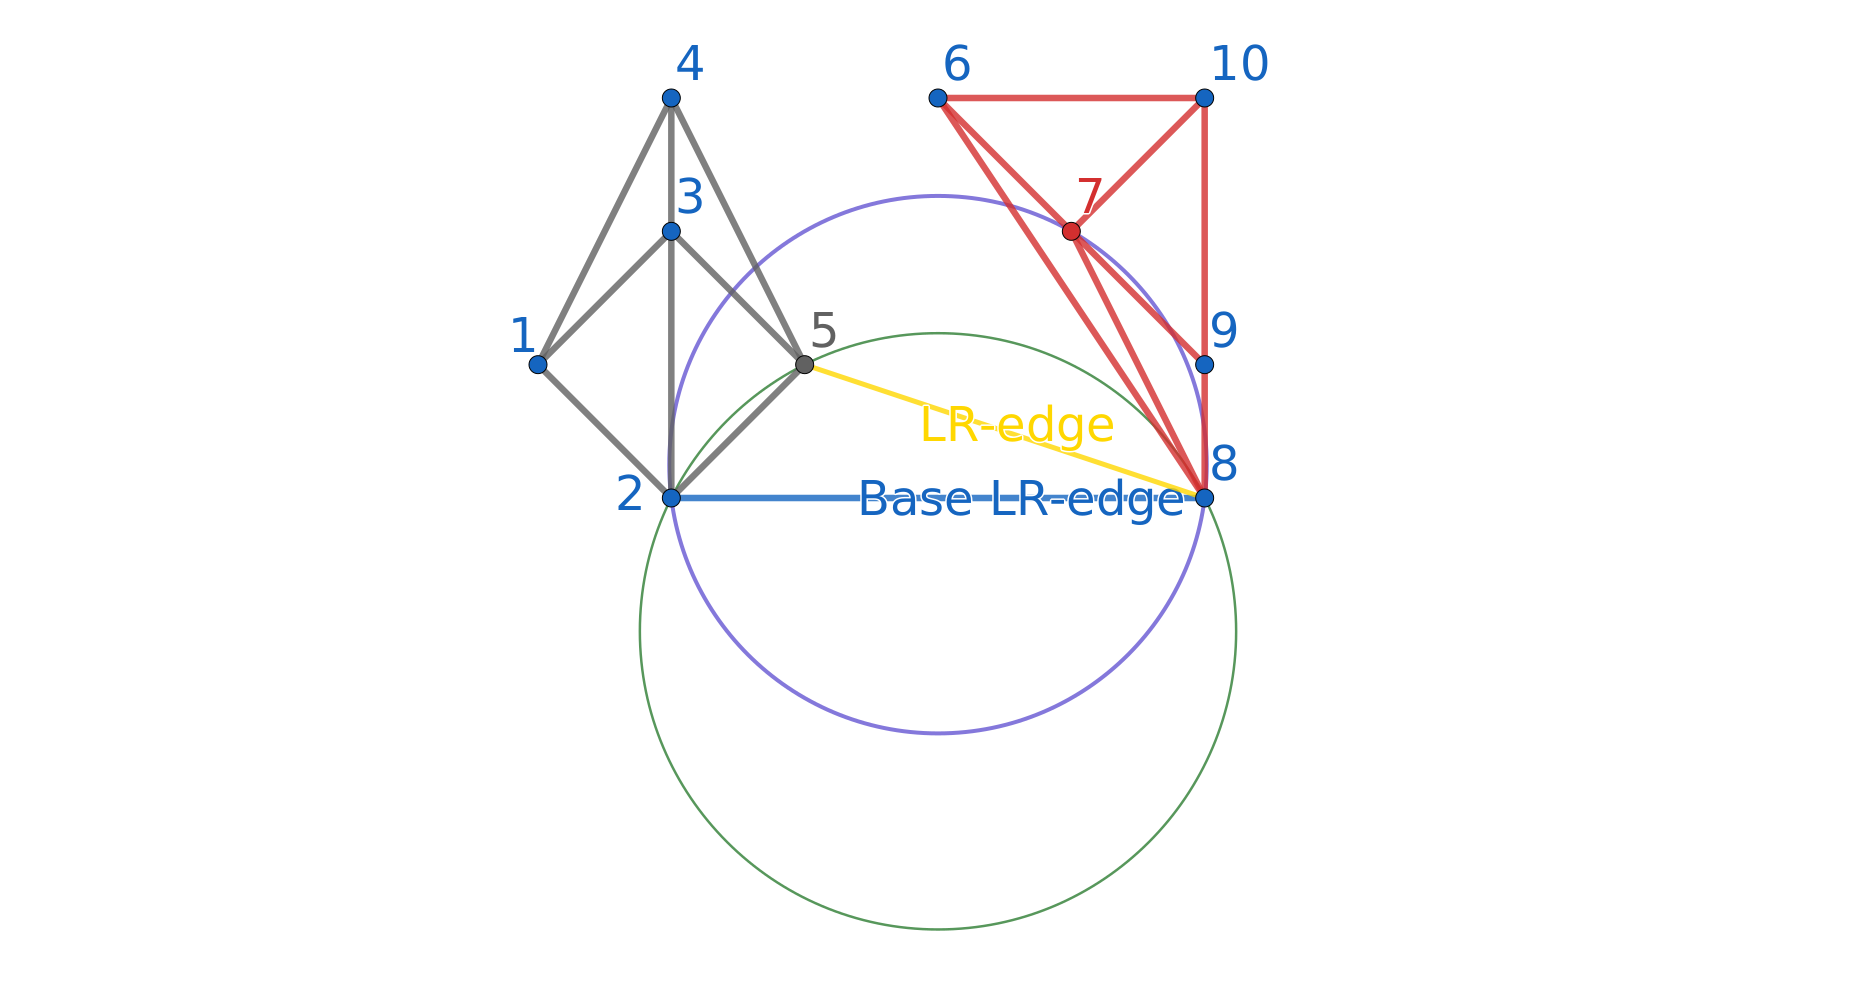
When LR-edge , base LR-edge , , merge .
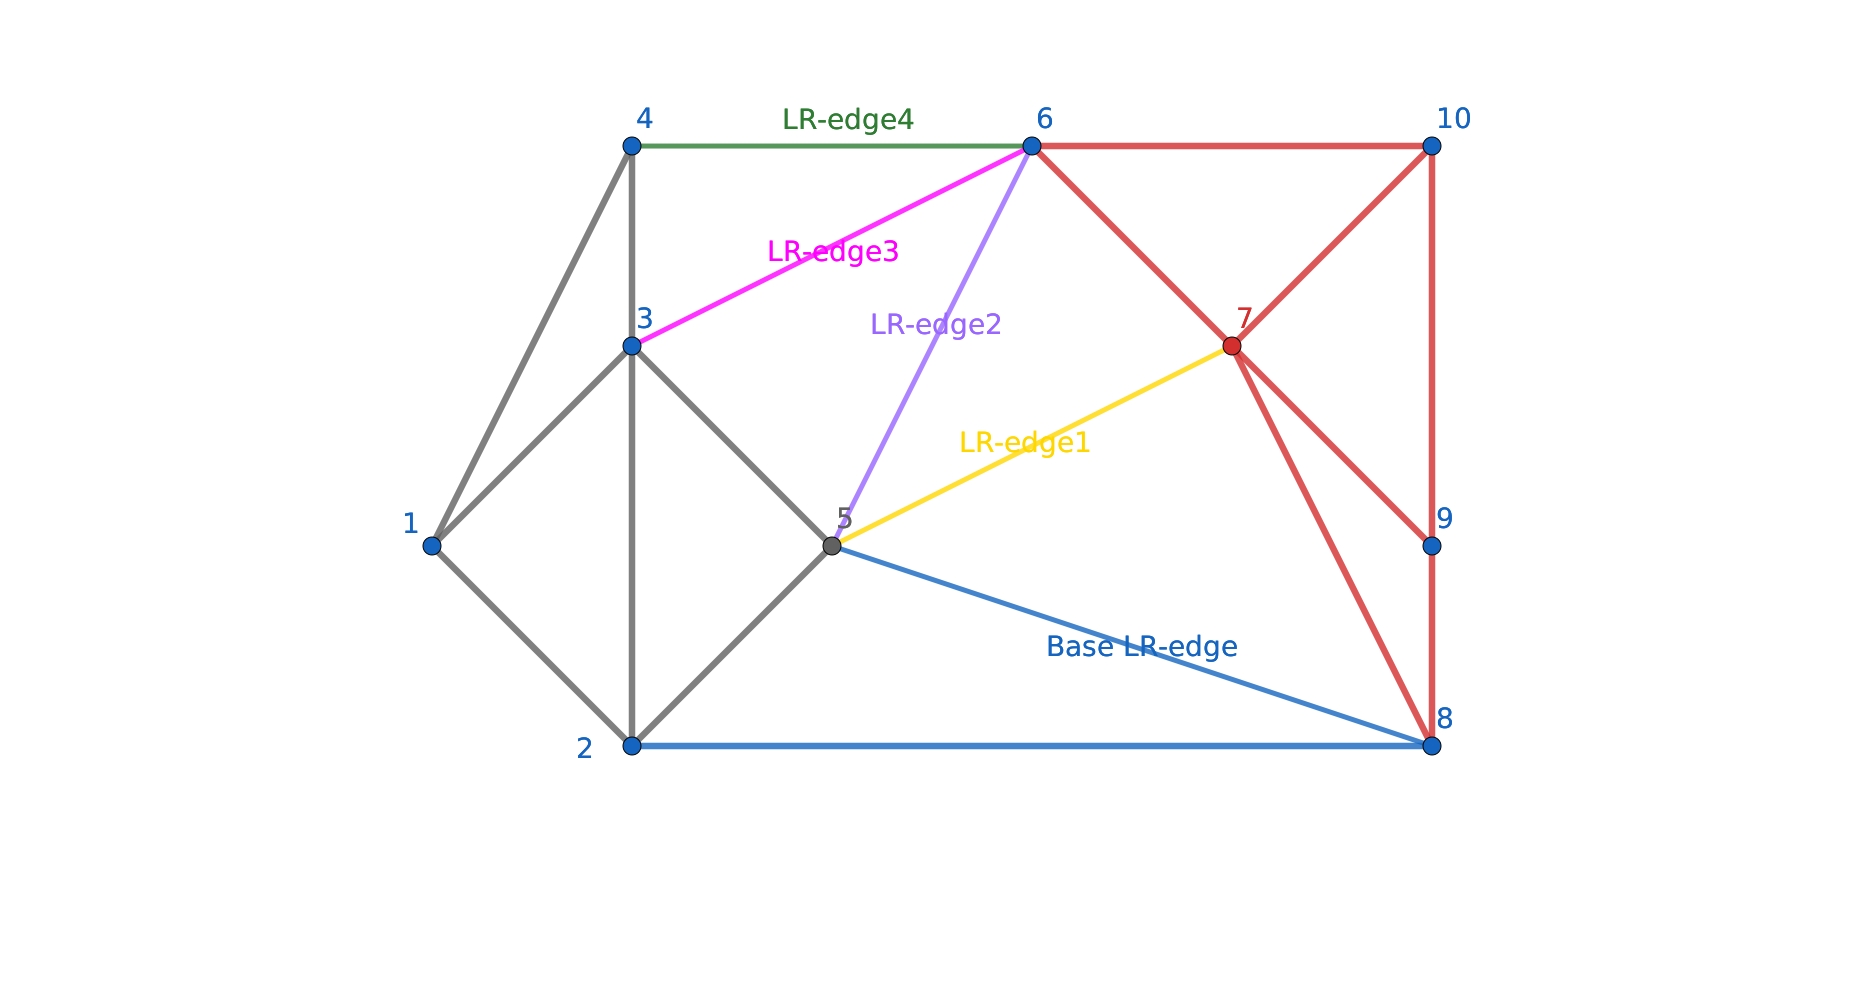
code
Implementation
#include <algorithm>
#include <cmath>
#include <cstring>
#include <list>
#include <utility>
#include <vector>

constexpr double EPS = 1e-8;
constexpr int MAXV = 10000;

struct Point {
  double x, y;
  int id;

  Point(double a = 0, double b = 0, int c = -1) : x(a), y(b), id(c) {}

  bool operator<(const Point &a) const {
    return x < a.x || (fabs(x - a.x) < EPS && y < a.y);
  }

  bool operator==(const Point &a) const {
    return fabs(x - a.x) < EPS && fabs(y - a.y) < EPS;
  }

  double dist2(const Point &b) {
    return (x - b.x) * (x - b.x) + (y - b.y) * (y - b.y);
  }
};

struct Point3D {
  double x, y, z;

  Point3D(double a = 0, double b = 0, double c = 0) : x(a), y(b), z(c) {}

  Point3D(const Point &p) { x = p.x, y = p.y, z = p.x * p.x + p.y * p.y; }

  Point3D operator-(const Point3D &a) const {
    return Point3D(x - a.x, y - a.y, z - a.z);
  }

  double dot(const Point3D &a) { return x * a.x + y * a.y + z * a.z; }
};

struct Edge {
  int id;
  std::list<Edge>::iterator c;

  Edge(int id = 0) { this->id = id; }
};

int cmp(double v) { return fabs(v) > EPS ? (v > 0 ? 1 : -1) : 0; }

double cross(const Point &o, const Point &a, const Point &b) {
  return (a.x - o.x) * (b.y - o.y) - (a.y - o.y) * (b.x - o.x);
}

Point3D cross(const Point3D &a, const Point3D &b) {
  return Point3D(a.y * b.z - a.z * b.y, -a.x * b.z + a.z * b.x,
                 a.x * b.y - a.y * b.x);
}

int inCircle(const Point &a, Point b, Point c, const Point &p) {
  if (cross(a, b, c) < 0) std::swap(b, c);
  Point3D a3(a), b3(b), c3(c), p3(p);
  b3 = b3 - a3, c3 = c3 - a3, p3 = p3 - a3;
  Point3D f = cross(b3, c3);
  return cmp(p3.dot(f));  // check same direction, in: < 0, on: = 0, out: > 0
}

int intersection(const Point &a, const Point &b, const Point &c,
                 const Point &d) {  // seg(a, b) and seg(c, d)
  return cmp(cross(a, c, b)) * cmp(cross(a, b, d)) > 0 &&
         cmp(cross(c, a, d)) * cmp(cross(c, d, b)) > 0;
}

class Delaunay {
 public:
  std::list<Edge> head[MAXV];  // graph
  Point p[MAXV];
  int n, rename[MAXV];

  void init(int n, Point p[]) {
    memcpy(this->p, p, sizeof(Point) * n);
    std::sort(this->p, this->p + n);
    for (int i = 0; i < n; i++) rename[p[i].id] = i;
    this->n = n;
    divide(0, n - 1);
  }

  void addEdge(int u, int v) {
    head[u].push_front(Edge(v));
    head[v].push_front(Edge(u));
    head[u].begin()->c = head[v].begin();
    head[v].begin()->c = head[u].begin();
  }

  void divide(int l, int r) {
    if (r - l <= 2) {  // #point <= 3
      for (int i = l; i <= r; i++)
        for (int j = i + 1; j <= r; j++) addEdge(i, j);
      return;
    }
    int mid = (l + r) / 2;
    divide(l, mid);
    divide(mid + 1, r);

    std::list<Edge>::iterator it;
    int nowl = l, nowr = r;

    for (int update = 1; update;) {
      // find left and right convex, lower common tangent
      update = 0;
      Point ptL = p[nowl], ptR = p[nowr];
      for (it = head[nowl].begin(); it != head[nowl].end(); it++) {
        Point t = p[it->id];
        double v = cross(ptR, ptL, t);
        if (cmp(v) > 0 || (cmp(v) == 0 && ptR.dist2(t) < ptR.dist2(ptL))) {
          nowl = it->id, update = 1;
          break;
        }
      }
      if (update) continue;
      for (it = head[nowr].begin(); it != head[nowr].end(); it++) {
        Point t = p[it->id];
        double v = cross(ptL, ptR, t);
        if (cmp(v) < 0 || (cmp(v) == 0 && ptL.dist2(t) < ptL.dist2(ptR))) {
          nowr = it->id, update = 1;
          break;
        }
      }
    }

    addEdge(nowl, nowr);  // add tangent

    for (int update = 1; true;) {
      update = 0;
      Point ptL = p[nowl], ptR = p[nowr];
      int ch = -1, side = 0;
      for (it = head[nowl].begin(); it != head[nowl].end(); it++) {
        if (cmp(cross(ptL, ptR, p[it->id])) > 0 &&
            (ch == -1 || inCircle(ptL, ptR, p[ch], p[it->id]) < 0)) {
          ch = it->id, side = -1;
        }
      }
      for (it = head[nowr].begin(); it != head[nowr].end(); it++) {
        if (cmp(cross(ptR, p[it->id], ptL)) > 0 &&
            (ch == -1 || inCircle(ptL, ptR, p[ch], p[it->id]) < 0)) {
          ch = it->id, side = 1;
        }
      }
      if (ch == -1) break;  // upper common tangent
      if (side == -1) {
        for (it = head[nowl].begin(); it != head[nowl].end();) {
          if (intersection(ptL, p[it->id], ptR, p[ch])) {
            head[it->id].erase(it->c);
            head[nowl].erase(it++);
          } else {
            it++;
          }
        }
        nowl = ch;
        addEdge(nowl, nowr);
      } else {
        for (it = head[nowr].begin(); it != head[nowr].end();) {
          if (intersection(ptR, p[it->id], ptL, p[ch])) {
            head[it->id].erase(it->c);
            head[nowr].erase(it++);
          } else {
            it++;
          }
        }
        nowr = ch;
        addEdge(nowl, nowr);
      }
    }
  }

  std::vector<std::pair<int, int>> getEdge() {
    std::vector<std::pair<int, int>> ret;
    ret.reserve(n);
    std::list<Edge>::iterator it;
    for (int i = 0; i < n; i++) {
      for (it = head[i].begin(); it != head[i].end(); it++) {
        if (it->id < i) continue;
        ret.push_back(std::make_pair(p[i].id, p[it->id].id));
      }
    }
    return ret;
  }
};
Voronoi graph
Voronoi graph polygon ,According to plane , planedivide into , each .
Voronoi graph Delaunay triangulation graph,canuse Delaunay triangulation algorithmfind , use algorithmfind graphImplementation time complexity Voronoi graph.
SGU 383 Caravans triangulation +
ContestHunter. triangulationfind graph Voronoi graph
Codeforces Gym 103485M. Constellation collection triangulation graph row Floodfill